OUR TECHNOLOGY
From small robots,
to systems that move together.
Robot hardware, cooperative transport, spatial perception, and robot intelligence.
Explore the technologies developed through physical prototypes and research experiments.
01 / ROBOT HARDWARE
Attach securely.
Move freely.
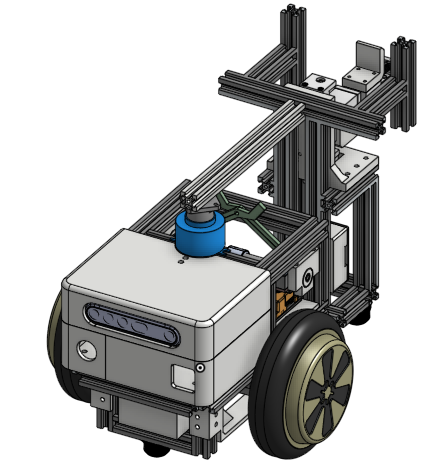
A compact drive module that attaches directly to the object being moved. Its design combines secure attachment with rotation in place.
We built a mechanism that can rotate 360 degrees in place while maintaining its grip on an object.
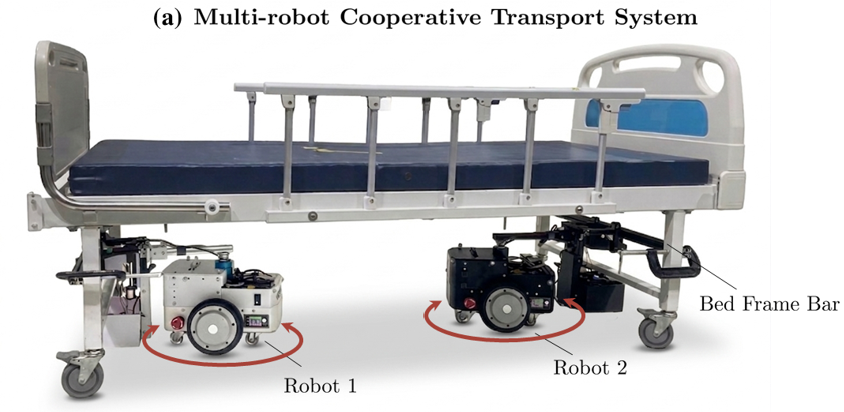
A physical research system with two robots attached to a hospital bed frame.
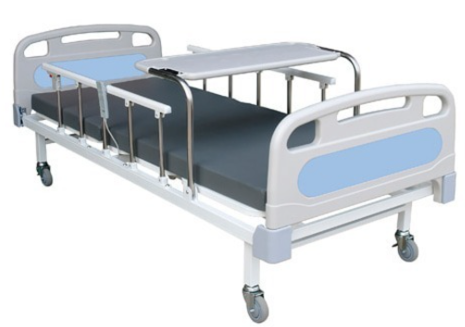
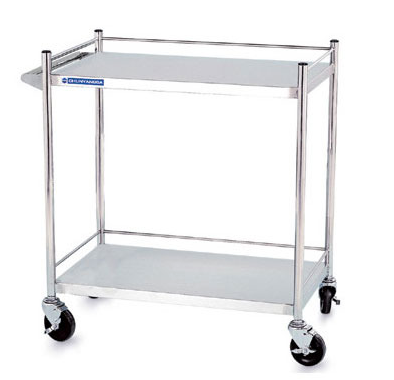
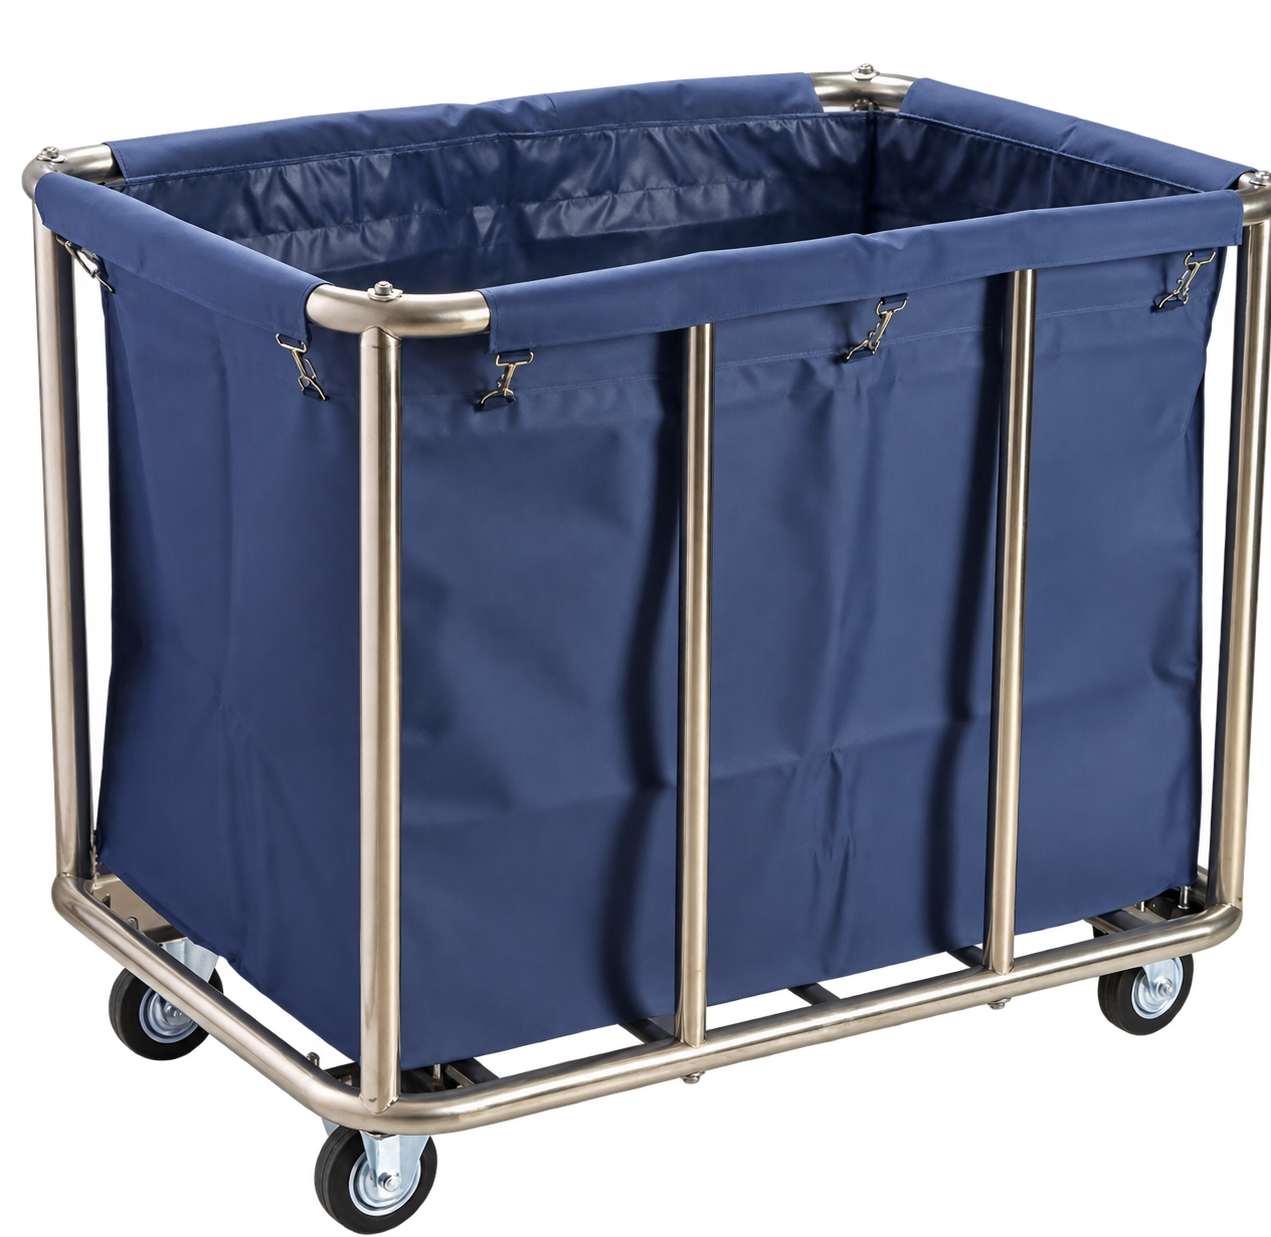
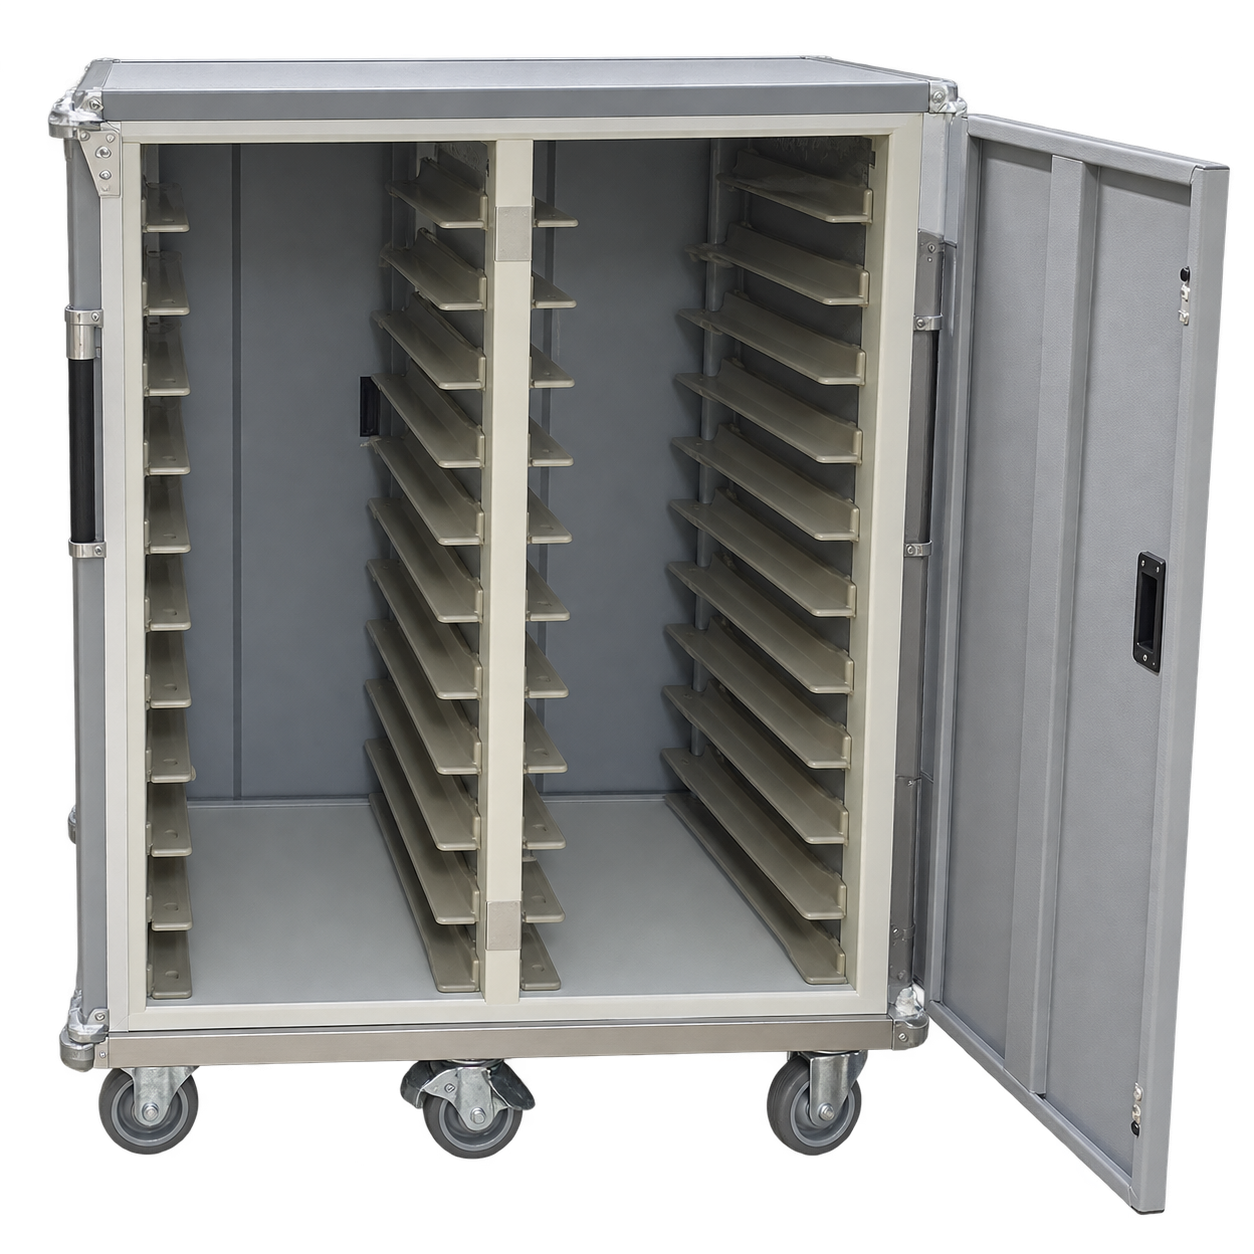
Building on bed transport experiments, we are exploring applications to other types of objects.
02 / COOPERATIVE TRANSPORT
Multiple robots.
One coordinated movement.
We consider the object's structure alongside the robots' drive constraints, connecting path planning with cooperative control.
We plan the object's path while accounting for attachment geometry and drive constraints.
The video could not be loaded. Try playing it in a new window.
We coordinate robot velocities and account for coupling constraints to follow the planned path.
The video could not be loaded. Try playing it in a new window.
Research on a small assistive robot that approaches a wheelchair, attaches to it, and supports mobility.
The video could not be loaded. Try playing it in a new window.
03 / SPATIAL PERCEPTION
From observations,
to meaningful maps.
We estimate surrounding geometry and the current position, integrate observations into a shared map, and extend it with semantic understanding.
We scanned a hospital environment with a stereo camera, reconstructed a point cloud map, and estimated the current position.
The video could not be loaded. Try playing it in a new window.
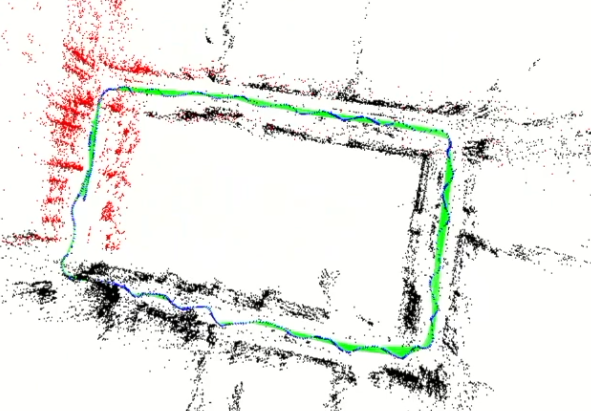
We combine observations and partial maps from multiple robots to build a shared map.
The video could not be loaded. Try playing it in a new window.
We identify semantic categories in a scene and incorporate them into a 3D map.
The video could not be loaded. Try playing it in a new window.
04 / ROBOT INTELLIGENCE
Perceive. Reason.
Then act.
Our research spans obstacle-aware motion planning and robot intelligence that turns human instructions into actions.
Research on detecting people and obstacles and planning robot motion.
The video could not be loaded. Try playing it in a new window.
Given human instructions, the system interprets the scene, breaks the task into subtasks, and selects skills or generates code.
The video could not be loaded. Try playing it in a new window.
This research was conducted with drones. It does not represent a function deployed on hospital robots.
WHAT’S NEXT